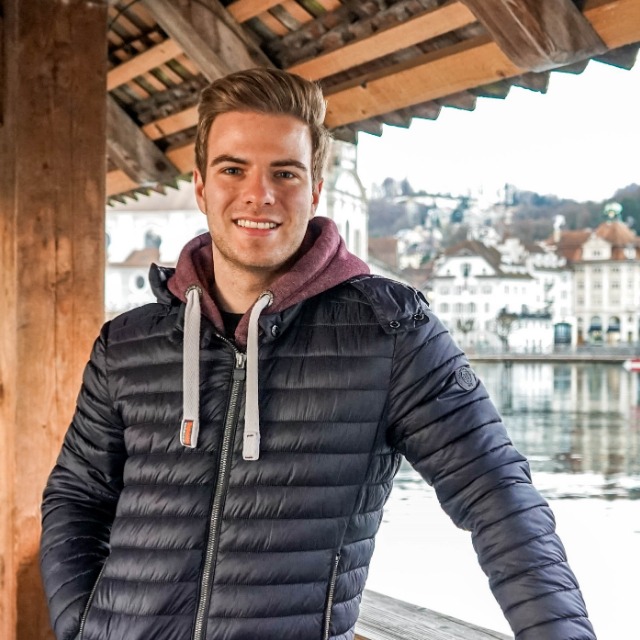
Hi, I’m Marcus.
PhD Student·Karlsruhe Institute of Technology
I am a PhD student at the Applied Technical-Cognitive Systems group at the Karlsruhe Institute of Technology, where I am supervised by Prof. Dr.-Ing. Johann Marius Zöllner.
My research focuses on learning robot policies from large-scale, unlabeled video. Prevailing approaches rely on carefully curated, action-labeled demonstrations, which are costly to obtain and limited in behavioral diversity. I investigate how transferable action representations can instead be extracted from the abundance of human-activity video available on the web, such as footage of people cooking, assembling, repairing, and otherwise interacting with the physical world, so that agents can acquire generalizable skills without bespoke dataset construction for every downstream task. I am particularly interested in vision-language-action models, world models, and how imitation learning and reinforcement learning can be efficiently utilized to ground such representations in robust, executable behavior.
Before my PhD I finished my M.Sc. in Electrical Engineering and Information Technology, also at KIT. Outside of research, I’m into sim racing, motorsports, and all action-packed things.
News
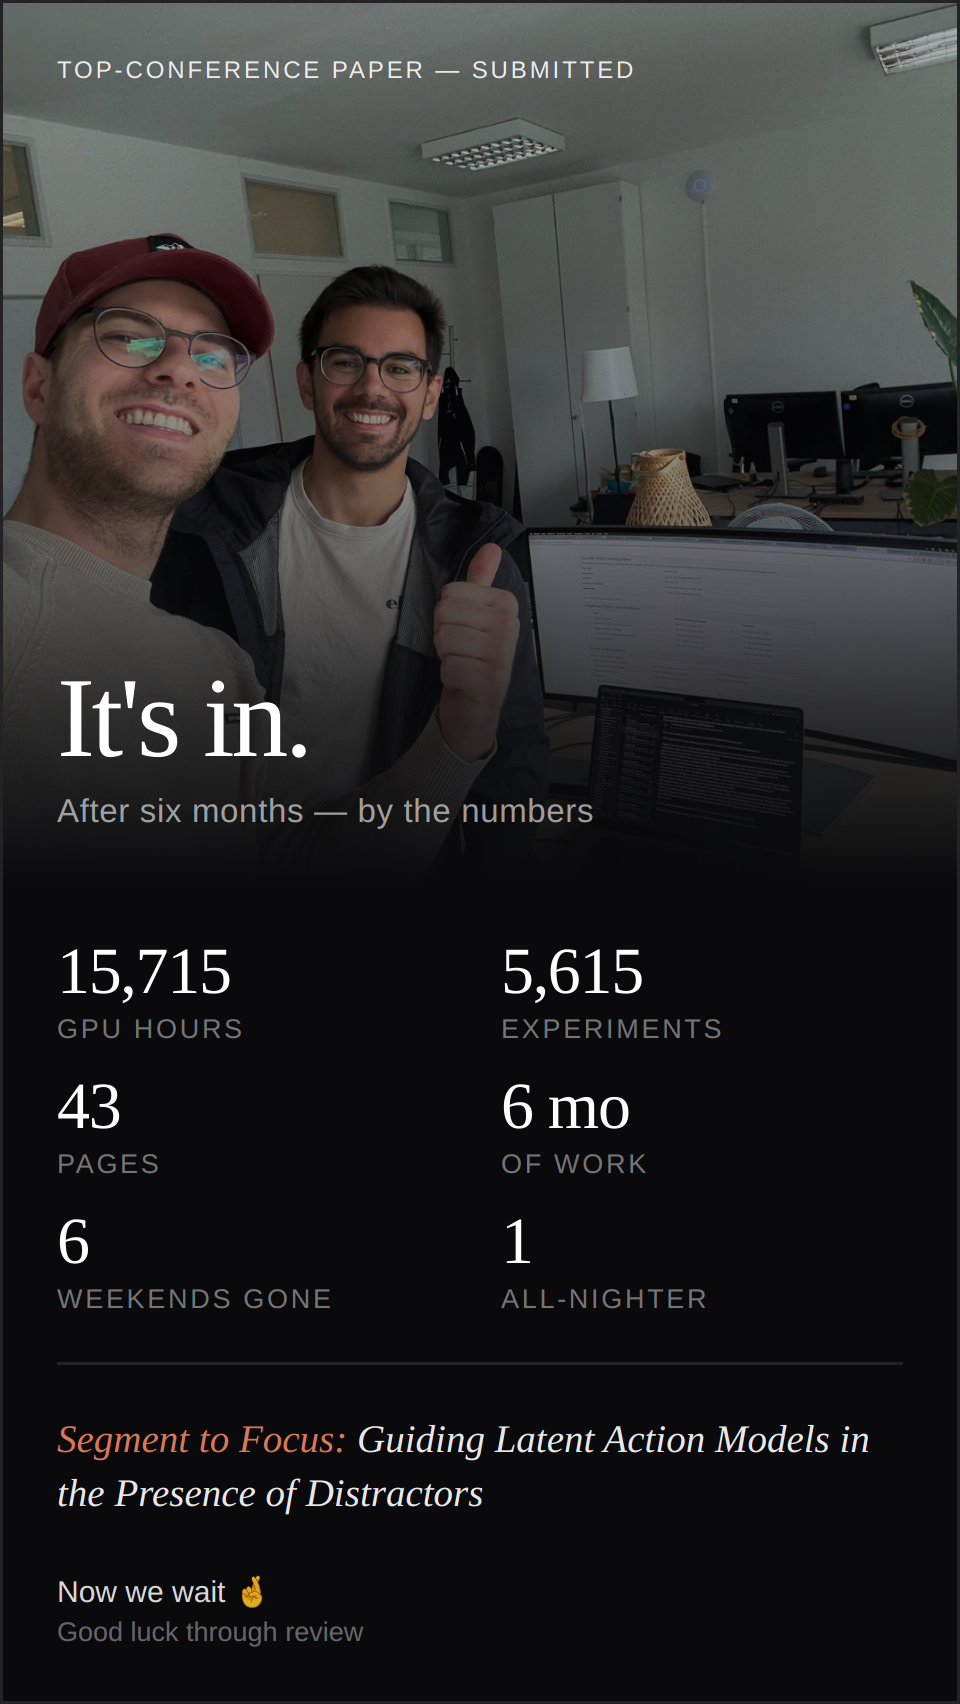
- Released our preprints “Segment to Focus: Guiding Latent Action Models in the Presence of Distractors” and “CIG: Exploration via Conditional Information Gain” on arXiv — both under review, fingers crossed 🤞 Image
- Joined KIT as a doctoral researcher.
Publications
2026
-

Segment to Focus: Guiding Latent Action Models in the Presence of Distractors
arXiv preprint
@misc{fechner2026segmentfocusguidinglatent, title={Segment to Focus: Guiding Latent Action Models in the Presence of Distractors}, author={Marcus Fechner and Hamza Adnan and Constantin C. Lüth and Matthew T. Jackson and Alexey Zakharov and J. Marius Zöllner}, year={2026}, eprint={2602.02259}, archivePrefix={arXiv}, primaryClass={cs.LG}, url={https://arxiv.org/abs/2602.02259}, } -
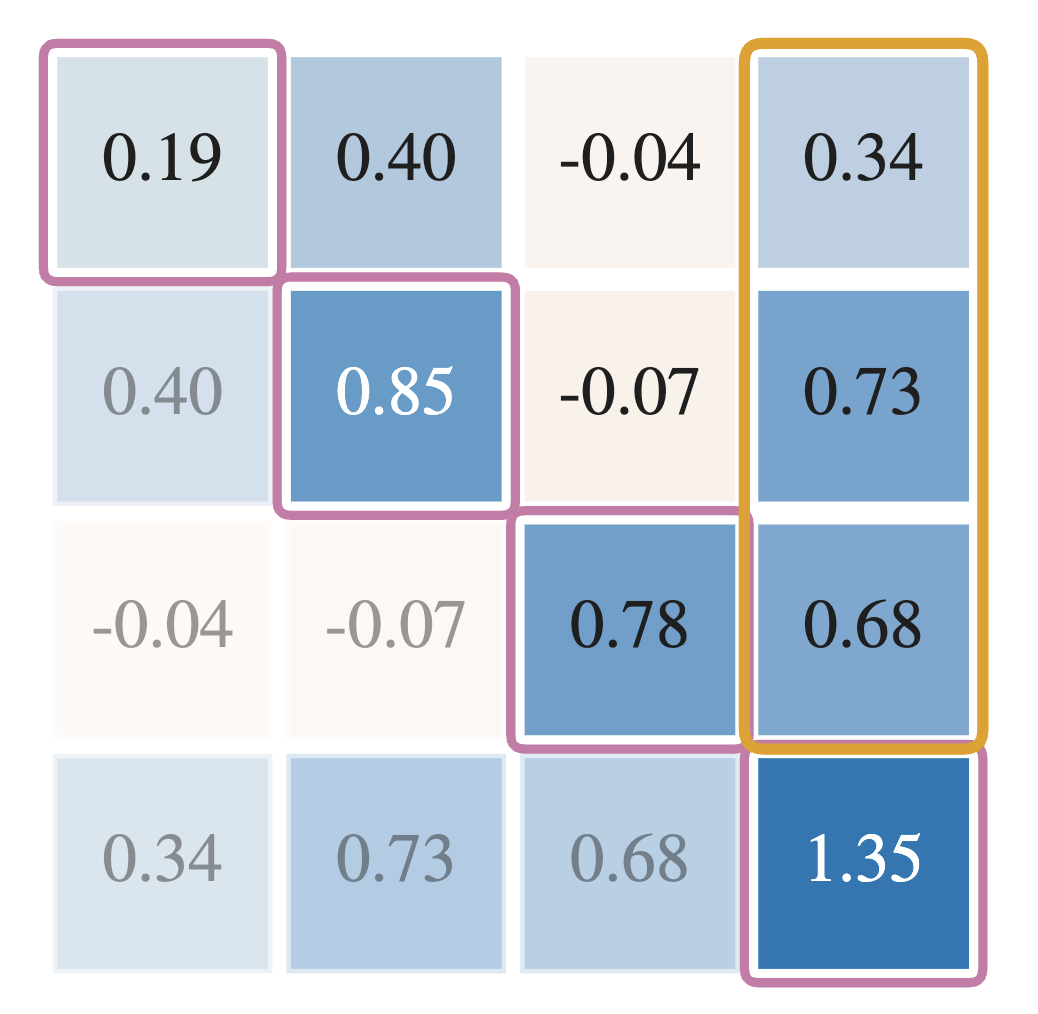
CIG: Exploration via Conditional Information Gain
arXiv preprint
@misc{joseph2026cigexplorationconditionalinformation, title={CIG: Exploration via Conditional Information Gain}, author={Tim Joseph and Marcus Fechner and Philipp Stegmaier and Karam Daaboul and J. Marius Zöllner}, year={2026}, eprint={2605.20878}, archivePrefix={arXiv}, primaryClass={cs.LG}, url={https://arxiv.org/abs/2605.20878}, }
Teaching
-
WS 22/23 — now
Machine Learning 1 – FundamentalsTeaching Assistant
Inductive learning · Learning theory · Decision trees · SVMs · Neural networks · CNNs · Unsupervised learning · Bayesian learning · Reinforcement learning · NLP · Sequence models
-
SS 23 — now
Machine Learning 2 – Advanced MethodsTeaching Assistant
Policy- & model-based RL · Active learning · Uncertainty in deep neural networks · Transformers · Advanced computer vision · Large-scale training · GANs · Graph neural networks · Diffusion models · Variational autoencoders
Experience
-
Doctoral Researcher
Karlsruhe Institute of Technology
Jun 2022 — Present
Researching how agents can learn transferable skills from unlabeled web video.
-
Internship, Applied Technical-Cognitive Systems
FZI Research Center for Information Technology
Sep 2019 — Feb 2020
Combined Monte Carlo Tree Search and deep neural networks to accelerate motion planning for cooperative multi-agent driving.
-
Internship, R&D Autonomous Driving
Mercedes-Benz AG
Jun 2017 — Oct 2017
Optimized convolutional neural networks for efficient deployment on embedded automotive hardware.
-
Internship, R&D Autonomous Driving
Mercedes-Benz AG
Aug 2016 — Jan 2017
Built a minimal embedded Linux image with the Yocto Project to evaluate hardware platforms for autonomous driving.